
Presentation
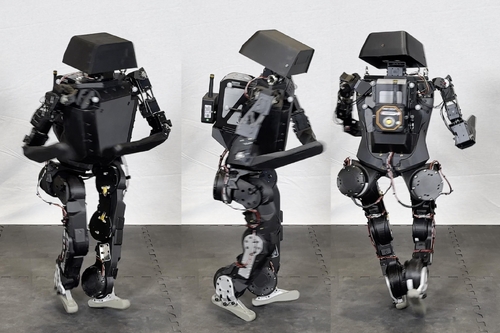
AMOR: Adaptive Character Control through Multi-Objective Reinforcement Learning
SessionRobots in the World
DescriptionPresenting AMOR, a policy conditioned on context and a linear combination of reward weights, trained using multi-objective reinforcement learning. Once trained, AMOR allows for on-the-fly adjustments of reward weights, unlocking new possibilities in physics-based and robotic character control.
Event Type
Technical Paper
TimeWednesday, 13 August 20259:10am - 9:20am PDT
LocationWest Building, Rooms 118-120
ACM Digital Library
Journal Papers' PDFs
Conference Papers' PDFs
Conference Papers' PDFs
Session Time & Location
Sunday, 10 August 20256:00pm - 8:45pm PDTWest Building, Ballroom AB
Wednesday, 13 August 20259:00am - 10:30am PDTWest Building, Rooms 118-120
Not Livestreamed
Not Recorded
