
Presentation
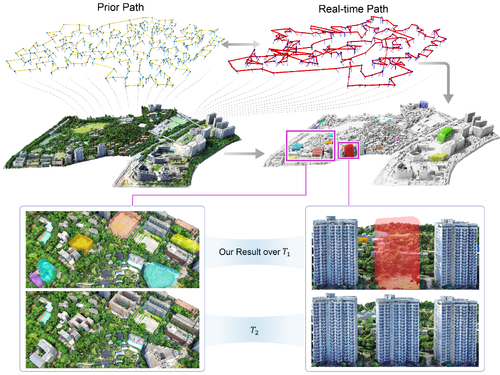
Aerial Path Online Planning for Urban Scene Updation
SessionRobots in the World
DescriptionWe present the first scene-update aerial path planning algorithm specifically designed for detecting and updating change areas in urban environments, which paves the way for efficient, scalable, and adaptive UAV-based scene updates in complex urban environments.
Event Type
Technical Paper
TimeWednesday, 13 August 20259:50am - 10:00am PDT
LocationWest Building, Rooms 118-120
ACM Digital Library
Journal Papers' PDFs
Conference Papers' PDFs
Conference Papers' PDFs
Session Time & Location
Sunday, 10 August 20256:00pm - 8:45pm PDTWest Building, Ballroom AB
Wednesday, 13 August 20259:00am - 10:30am PDTWest Building, Rooms 118-120
Livestreamed
Recorded
